
Stall Detection and Motor Protection Setup on SOLO
Set up stall detection and motor protection on SOLO: configure the stall time, current and fault response to protect your motor from a locked rotor.
201 articles
Set up stall detection and motor protection on SOLO: configure the stall time, current and fault response to protect your motor from a locked rotor.
How to choose the PWM switching frequency on SOLO, why low-inductance motors need a higher frequency, and the trade-offs with heat and ripple.
How to build a motor efficiency map on a test bench: the measurement method, the torque-speed grid, and what the map reveals about a motor.

Production tips for Python motor control on Raspberry Pi with SOLO: SoloPy setup, robust serial/CAN, threading, error recovery and reliable deployment.
How to spin a motor in open-loop manual mode on SOLO with potentiometers and no programming. When open loop is enough, and its limits.
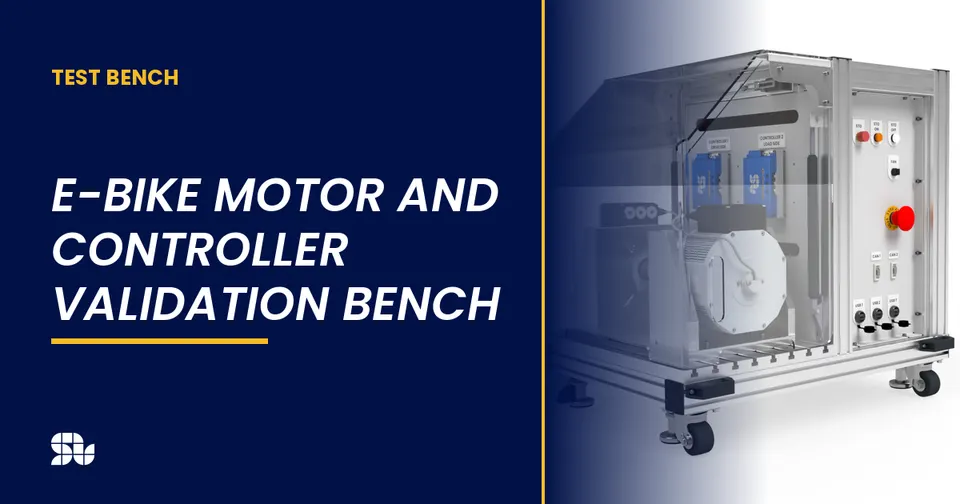
How to validate an e-bike motor and controller on a bench: torque and cadence, assist profiles, regen and the metrics that matter for e-bikes.
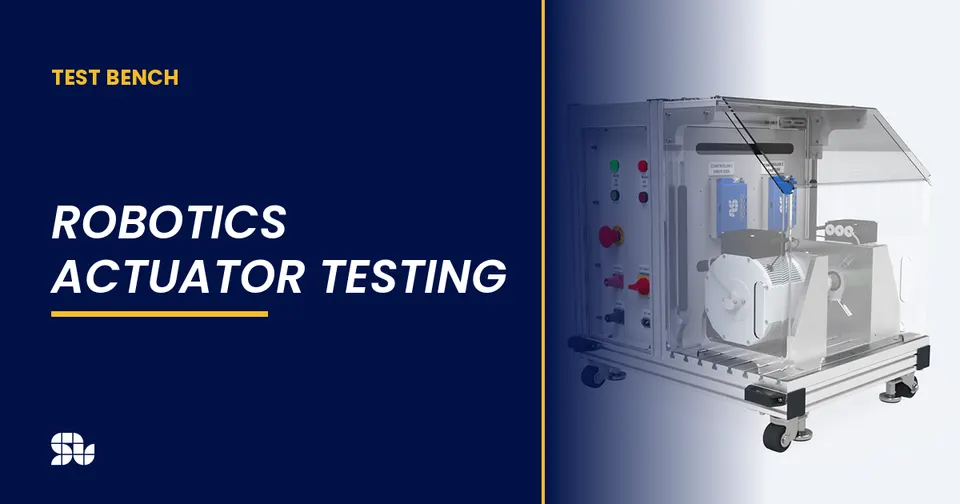
How to validate motors and actuators for robots on a test bench: torque density, backlash, repeatability and the metrics that matter for robotics.
Analog or digital command mode on SOLO? Compare analog inputs vs UART, USB and CAN control to pick the right command interface for your project.
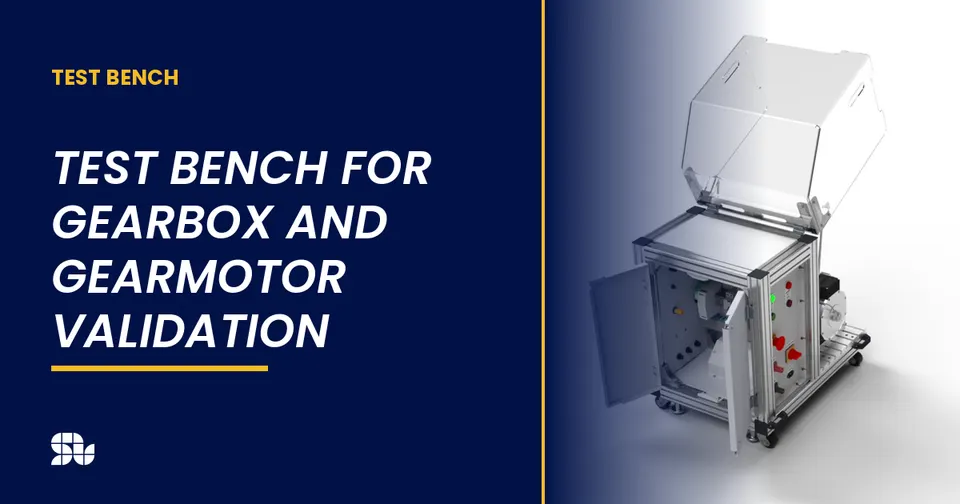
How to validate a gearbox or gearmotor on a test bench: efficiency, backlash, ratio verification, and the load setup gearmotors need.

How EtherCAT motor control works with the SOLO SOM: CoE and CiA 402, distributed clocks, cyclic synchronous modes and wiring a deterministic servo network.

Cogging torque vs torque ripple explained: what causes cogging, how it differs from torque ripple, when each matters, and how FOC and design reduce them.
How to set speed acceleration and deceleration ramps on SOLO for smooth motion, and how the decel ramp ties into regenerative braking.

Discover our High-Performance Motor Controllers, Test Benches, and Services trusted worldwide.