
Disable/Enable Drive and Freewheeling: Safe Motor Stopping
Introduction
A motor at 4000 RPM can take several seconds to coast to rest with no load fighting it. How you end that motion matters as much as how you start it. Cut the power stage and the motor freewheels. Command a ramp instead and it stops on your terms. The two paths feel similar from a button, but they differ in stopping time, mechanical wear, and safety.
This guide explains how disable and enable drive work on SOLO, how freewheeling differs from a controlled stop, and how to set the power-on state so the motor does not move when you do not expect it. If you manage stop behavior on a machine, you will know which method to use for each case by the end.
Disable vs Enable Drive
The drive has two basic states. When the drive is enabled, the power stage is active. The controller switches the output transistors and the motor is under control, holding a torque, speed, or position command. When the drive is disabled, the outputs open. The power stage stops switching, no current flows to the windings, and the motor is no longer driven.
Think of disable as letting go of the wheel, not as braking. The controller still has power and still talks to you over the Motion Terminal. It simply stops commanding the motor. That distinction is the root of everything below: a disabled drive applies no torque, so the load decides what happens next.
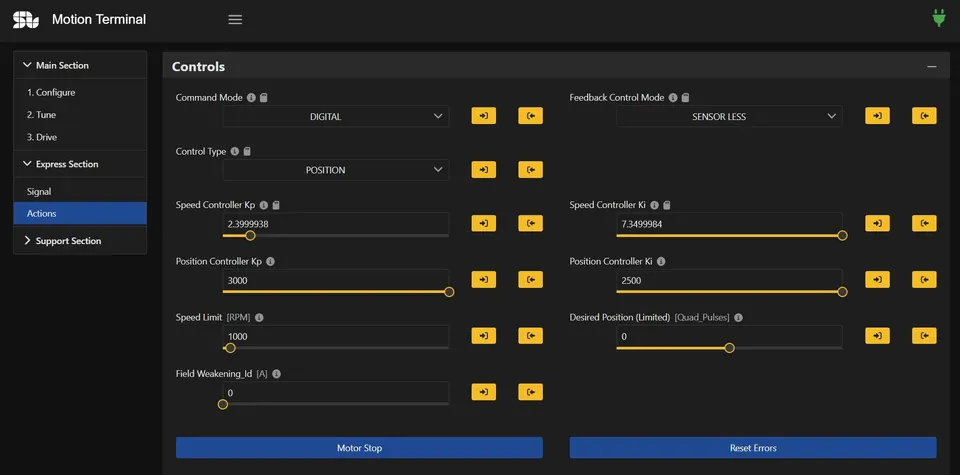
Takeaway: enable means the power stage drives the motor; disable means the outputs open and the motor coasts.
Freewheeling vs Controlled Stop
What Freewheeling Means
When you disable the drive, the motor freewheels. The outputs are open, so the controller applies no torque in either direction. The rotor keeps spinning on its own inertia and slows down only from friction, windage, and whatever the load adds. A light, low-friction load can coast for a long time. A geared load with high friction stops fast on its own.
Freewheeling is what you want when the machine should be free to move by hand, or when you simply want the motor to stop driving without forcing a stop point. It is the gentlest option on the gearbox and couplings, because no braking force runs through the drivetrain. The trade-off is that you give up control of the stopping time and the final position.
What a Controlled Stop Means
A controlled stop is the opposite approach. Instead of opening the outputs, the controller keeps the drive enabled and commands a deceleration ramp down to zero speed. The motor stays under control the whole way, so you decide how fast it stops and where it ends up. This is the right method when a sudden coast would overshoot a target or let a vertical load drop.
A controlled stop usually pushes energy back from the motor into the bus while it decelerates. That is regeneration, and on a fast ramp it can raise the bus voltage, so the drive needs a way to handle it. The ramp time itself is part of your motion profile, set by the acceleration and deceleration limits you configure.
Choosing Between Them
Neither method is better in every case. Match the method to what the application needs: a free axis, or a defined stop point.
| Factor | Freewheeling (disable drive) | Controlled stop (ramp) |
|---|---|---|
| Stopping time | Set by inertia and friction, not controlled | You set it with the deceleration ramp |
| Mechanical wear | Low, no braking force in the drivetrain | Higher on a fast ramp, force runs through gears |
| Final position | Wherever the load coasts to | Defined and repeatable |
| Safety | Motor free to move, can be pushed by the load | Holds against the load until stopped |
| Regenerated energy | None, no braking torque | Pushed back to the bus, more on a fast ramp |
Takeaway: freewheel when the axis should be free, ramp when you need a defined, repeatable stop.
Power-On Behavior
What the drive does at power-up is a safety question, not a detail. If a controller comes up enabled with a stored command, the motor can start moving the moment you apply power. On a machine with an operator nearby, an unexpected move is a hazard. So you should set the power-on state on purpose, not leave it to chance.
A common safe default is to power on with the drive disabled, then enable it from a known, deliberate step in your sequence. That way the motor stays still until your logic, or the operator, asks for motion. Set the command source and any stored setpoint to match, so the first enable does not jump to an old target. Configure this once during commissioning and the behavior is predictable on every boot.
Takeaway: choose the power-on state on purpose so the motor never moves before you ask it to.
Configuring Disable/Enable in Motion Terminal
You set the drive state in the Motion Terminal, the same software you use to commission and tune the motor. From there you can enable or disable the drive directly, and you can route the command to a hardware input so the machine controls it in operation. This is useful when a PLC, a switch, or a safety chain needs to gate the motor.

The command can come from software or from a digital input wired to your control logic. A digital input gives a clean on/off signal that fits an enable line well. An analog input, by contrast, suits a continuous setpoint like speed, not a simple on/off state. Pick the source that matches how the rest of the machine is wired, and keep it consistent with your power-on state.
Takeaway: configure the drive state once in Motion Terminal and route it to a digital input when the machine should control it.
Disable Drive vs Safe Torque Off
It is easy to assume that disabling the drive is a safety function. It is not, and treating it as one is a real risk. Disabling the drive opens the outputs in firmware, but it relies on the controller working correctly. A fault, a glitch, or a wiring problem could leave the situation different from what you intended. For routine stops that is fine. For protecting a person, it is not enough on its own.

Safe Torque Off, or STO, is the certified safety function for this job. STO removes the drive’s ability to produce torque through a dedicated hardware path, independent of the normal control logic, and it is built to a recognized safety standard. Use STO where a standard or a risk assessment calls for a safety stop. Use disable drive for normal operational stops. To see how STO is wired and used on SOLO, read our guide to Safe Torque Off.

Takeaway: disable drive is an operational stop, STO is the certified safety function, and they are not interchangeable.
How SOLO Helps You Stop a Motor Safely
SOLO controllers support both ways of stopping a motor from the Motion Terminal. You can disable the drive to let the motor freewheel, or command a deceleration ramp for a controlled stop, and you can set the power-on state so the motor stays still until you ask for motion. For applications that need a certified safety stop, supported controllers also provide a hardware Safe Torque Off path that is separate from the normal control logic. The aim is to give you a predictable stop for each case, from a routine coast-down to a safety event. You can explore the workflow on the SOLO Motion Terminal page.
Conclusion
Stopping a motor comes down to a clear choice. Disable the drive and the motor freewheels, with no torque and a coast-down set by inertia. Keep it enabled and ramp the speed for a controlled stop with a defined end point. Set the power-on state to disabled, as a rule, so the motor does not move before your sequence asks for it. And remember that disable drive is an operational stop, while Safe Torque Off is the certified safety function for protecting people. To set this up on your own motor, the SOLO Motion Terminal page is a good next step.
FAQ
What is the difference between disabling the drive and a controlled stop?
Disabling the drive opens the power stage outputs, so the motor applies no torque and freewheels to a stop on its own inertia. A controlled stop keeps the drive enabled and commands a deceleration ramp, so the motor stays under control and stops at a defined point in a time you set.
Does the motor brake when I disable the drive?
No. When you disable the drive, the outputs open and the controller applies no torque in either direction. The motor coasts and slows only from friction, windage, and the load. If you need active braking, use a controlled stop with a deceleration ramp instead.
Is disable drive a safety function like STO?
No. Disabling the drive is an operational stop handled in firmware, not a certified safety function. Safe Torque Off removes torque through a dedicated hardware path that is independent of the normal control logic and built to a safety standard. Use STO where a risk assessment or standard requires a safety stop.
What state is the drive in after power-on?
That depends on how you configure it, which is exactly why you should set it on purpose. A common safe default is to power on with the drive disabled, then enable it from a deliberate step in your sequence. This keeps the motor still at boot and avoids an unexpected move.
Related articles
Stall Detection and Motor Protection Setup on SOLO
Set up stall detection and motor protection on SOLO: configure the stall time, current and fault response to protect your motor from a locked rotor.
PWM Frequency Selection for Low-Inductance Motors
How to choose the PWM switching frequency on SOLO, why low-inductance motors need a higher frequency, and the trade-offs with heat and ripple.
Open-Loop Manual Mode: Spinning a Motor with Potentiometers
How to spin a motor in open-loop manual mode on SOLO with potentiometers and no programming. When open loop is enough, and its limits.
