
How to Choose a Motor Controller: A Selection Guide
Introduction
Pick the wrong voltage or current rating, and you do not find out at the desk. You find out weeks later, when the controller trips under load, runs hot, or cannot talk to your PLC. A re-spec at that stage can push a project back by a month. Most of those misses trace back to a single decision made too early, with too little information.
This is a practical guide to how to choose a motor controller. We use a framework of 6 decisions, taken in order, that map your motor and your machine to the right product. Work through them and you will know what to specify before you compare parts or ask for a quote.

What a Motor Controller Does (and What “Right” Means)
A motor controller takes a command, like a target speed or torque, and drives the motor to meet it. It switches power to the windings, reads feedback, and closes the loop so the motor does what you asked under changing load. A simple motor driver only switches power on command. A controller adds the control loop, the protection, and the interface to your system.
So “right” is not the cheapest part that spins the motor. The right controller matches your motor type, your voltage and current, your feedback, your control mode, your communication, and your environment. Miss one and the controller still runs, but it limits the machine around it. For the basics of the most common motor it will drive, see our brushless motors guide.
Takeaway: a controller is the control loop plus the interface, not just a power stage.
The Selection Framework: 6 Decisions
Here is the short version before we go deep. Each decision answers one question you should be able to settle before you buy.
| # | Decision | Key question |
|---|---|---|
| 1 | Motor type | Is it DC, BLDC, PMSM, or induction? |
| 2 | Voltage and current | Does it cover my bus voltage and peak current? |
| 3 | Feedback | Do I need an encoder, halls, or sensorless? |
| 4 | Control mode | Am I commanding torque, speed, or position? |
| 5 | Communication | How does the controller talk to my system? |
| 6 | Environment | Where does it run, and what must it survive? |
1. Motor Type (DC, BLDC, PMSM, Induction)
Start here, because the motor decides much of the rest. A brushed DC motor needs simple H-bridge drive. A BLDC or PMSM needs electronic commutation and, for smooth torque, field oriented control. An AC induction motor needs a different control model again. A controller built for only one of these will not drive the others well.
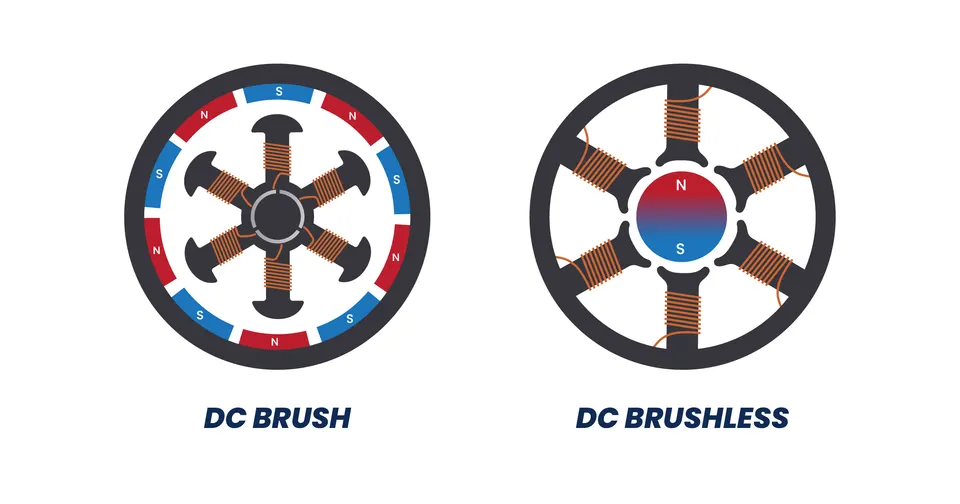
This guide owns the framework, not the deep motor-type call. If you are unsure which motor you have, compare a brushed motor vs a brushless motor, read up on the induction motor, or check what a servo motor needs from its drive. The practical tip is simple. If you run more than one motor type, or expect to switch later, a controller that covers all four saves you a redesign.
2. Voltage and Current Range
Now size the power. Write down your nominal bus voltage, and the continuous and peak current your motor draws at the worst operating point. The controller must cover all three with margin. A part that just meets your peak current will run hot and derate sooner than its datasheet suggests.
As a rule, size to your peak load with around 20% headroom, not to the average. Continuous current sets the thermal limit, peak current sets the torque you can hit for short bursts. As a reference point, SOLO controllers span roughly 8 to 60 V and 16 to 120 A across the range, which covers most low-voltage motors from a few watts up to several kilowatts.
Takeaway: match continuous current to your duty cycle, and peak current to your torque demand.
3. Feedback: Sensored vs Sensorless
Feedback tells the controller where the rotor is. You have two broad paths. Sensored uses an encoder or Hall sensors for an exact position, which you need for smooth low-speed torque and accurate positioning. Sensorless estimates position from the motor’s electrical signals, which saves wiring and cost but struggles near zero speed.
Pick sensored when you need full torque at standstill, precise position, or smooth motion at low RPM. Pick sensorless when the load spins up quickly, cost and wiring matter more than crawl-speed control, and you can live with weaker performance near zero. Many controllers support both, so you are not locked in. This is an overview, not a tuning guide.
Takeaway: sensored for precision and zero-speed torque, sensorless for simpler wiring at speed.
4. Control Mode: Torque, Speed, Position
Decide what you are actually commanding. There are three common control modes. Torque control sets the current, and so the force or torque, which suits tension control and force-limited tasks. Speed control holds a target RPM under changing load, which suits pumps, fans, and conveyors. Position control moves the shaft to an exact angle or location, which suits robotics and indexing.
Some applications layer these, like a position loop that rides on a speed loop. Make sure the controller supports the mode you need, in closed loop, at the response you expect. A controller that only runs open-loop speed will not hold a position.
Takeaway: name your output, torque or speed or position, before you compare controllers.
5. Communication and Protocols
Now connect it to your system. The interface decides how the controller takes commands and reports data. Common options are USB or UART for setup and simple links, analog or PWM for a basic command line, and field protocols like CANopen or EtherCAT for industrial machines that need many axes on one network with tight timing.

Match the protocol to where the controller lives. A benchtop project may need only USB. A machine on a factory line usually needs CANopen or EtherCAT to fit the existing control architecture. If you are heading toward an industrial setup with PLCs and multiple drives, plan the field protocol early, because retrofitting it later is painful.
Takeaway: choose the protocol your machine already speaks, not the one that is easiest at the desk.
6. Environment and Compliance
Last, the physical world. The controller must survive where it runs. Check the operating temperature range, the ingress protection against dust and water, and exposure to vibration or shock. A board rated for a clean lab can fail fast in a dusty, hot, vibrating machine.
Ingress protection is rated by an IP code, and the right code depends on your enclosure and location. Our guide to IP ratings explains what the two digits mean and how to pick. If your product ships to customers, factor in certification needs too, since the required marks depend on your market and sector.
Takeaway: rate the controller for the harshest condition it will see, not the average one.
Match Your Application to the Range
The six decisions narrow the field. Now map them to your case. The table below pairs a common scenario with what usually matters most, so you can see which decisions to weight.
| Application | Typical motor | What matters most |
|---|---|---|
| Robotics joint or actuator | BLDC or PMSM | Position control, sensored feedback, smooth low-speed torque |
| Pump, fan, or conveyor | Induction or BLDC | Speed control, continuous current, reliability |
| AGV or mobile robot drive | BLDC or PMSM | Battery voltage range, multi-axis, CANopen |
| Industrial machine axis | PMSM or induction | EtherCAT or CANopen, environment rating, compliance |
| Bench or prototype | Any | USB setup, flexible control modes, easy tuning |
Read your row, then go back and confirm the decisions it leans on. Robotics leans on feedback and control mode. A factory axis leans on protocol and environment. The same framework applies, only the weights change.
Takeaway: the decisions do not change by application, but their priority does.
Pros, Cons & Trade-offs
No single choice is free. Picking a controller is a set of trade-offs, and naming them keeps you honest. The table groups the common ones.
| Choice | Pro | Con | When it fits |
|---|---|---|---|
| Single-motor-type controller | Simple, often lower cost | Locks you to one motor | You will only ever run one motor type |
| Universal (DC/BLDC/PMSM/ACIM) | One part covers a roadmap | More features to learn | You run, or may run, several motor types |
| Sensored feedback | Precise, full torque at zero speed | Extra wiring and sensor cost | Positioning, low-speed torque |
| Sensorless feedback | Less wiring, lower cost | Weak near zero speed | Loads that spin up fast |
| Field protocol (CANopen/EtherCAT) | Fits industrial networks | More setup than USB | Multi-axis or factory machines |
The common mistake is optimizing for the cheapest part today and paying for it later in a redesign. If your motors, speeds, or interfaces may change, a flexible controller usually costs less over the life of the product than a narrow one you outgrow. If your requirements are fixed and simple, a focused part is fine.
Takeaway: trade cost against flexibility on purpose, with your roadmap in view.
The SOLO Controller Range at a Glance
SOLO controllers are designed as one universal platform, so the same controller can drive DC, BLDC, PMSM, and AC induction motors in torque, speed, or position mode. That keeps the framework above simple. You pick the power level, not a different control philosophy for each motor. The range spans four power tiers.

| Controller | Voltage range | Continuous current | Typical power |
|---|---|---|---|
| PICO | 8 to 58 V | up to 16 A | ~300 W class |
| MINI | 8 to 58 V | up to 32 A | ~500 W class |
| UNO | 8 to 58 V | up to 32 A | ~800 W class |
| MEGA | 8 to 58 V | up to 120 A | ~6 kW class |
Across the range you get sensored and sensorless feedback, multiple control modes, and communication from USB and UART up to CANopen and EtherCAT. So a project can start on a small board and scale up without changing how you tune or talk to the controller. You can browse the full SOLO motor controllers range and match a tier to the power level you sized in decision 2.
Conclusion
Choosing a motor controller comes down to six decisions, taken in order: motor type, voltage and current, feedback, control mode, communication, and environment. Settle the motor first, because it shapes the rest. Size the power to your peak load with headroom, pick feedback for the precision you need, name the control mode you actually command, and plan the protocol for where the controller will live. Get those right and the environment check is the final filter. If you want to map your sizing to a real product, the SOLO motor controllers range is a good next step, and our team can review your specs.
FAQ
How do I choose the right motor controller for my motor?
Start with the motor type, then size voltage and current to your peak load with margin. After that, pick feedback, control mode, communication, and environment rating. Working through those six decisions in order maps your motor to the right controller without guesswork.
What voltage and current rating do I need?
Match the controller’s voltage range to your nominal bus voltage, and its continuous current to your worst steady-state draw, with around 20% headroom. Check the peak current rating separately, because that sets the short-burst torque you can hit. Sizing only to the average current usually leads to thermal derating later.
Do I need a sensored or sensorless controller?
Choose sensored, using an encoder or Hall sensors, when you need precise positioning or full torque at standstill. Choose sensorless when wiring and cost matter more and the load spins up quickly. Sensorless control is generally weaker near zero speed, so it fits applications that do not dwell there.
Can one controller drive DC, BLDC, PMSM and induction motors?
Yes, if it is built as a universal platform. A controller that supports all four motor types lets you run DC, BLDC, PMSM, and AC induction motors without changing the core hardware. That is useful when you run several motor types or expect your design to change.
Related articles

DC vs BLDC vs PMSM vs Induction: Which Controller You Need
DC vs BLDC vs PMSM vs induction: how each motor type maps to the controller it needs, with commutation, feedback and drive-mode differences explained.

Choosing Motor Controllers for Industrial Machines
How to choose a motor controller for industrial machines: environment, field protocols, robustness, integration with PLCs and Industry 4.0 connectivity.

Motor Controller Certifications (UL, CE, IEC) for OEMs
What UL, CE and IEC certifications mean for motor controllers, which OEMs need them, and how compliance affects controller selection and market access.
