
Magnetizing Current (Id) for Induction Motors in FOC
Introduction
On a permanent-magnet motor you set the d-axis current to roughly zero and forget it. On an AC induction motor you cannot. An induction motor has no magnets, so it needs a magnetizing current, called Id, just to build the rotor flux that makes torque possible. Set Id too low and the motor feels weak. Set it too high and the motor runs hot for no extra torque.
This article explains what the Id magnetizing current does in field-oriented control (FOC), how to size it for your induction motor, and where to set it in SOLO Motion Terminal. The short answer: start near the motor’s no-load current, then trim it while you watch torque and temperature.
Why Induction Motors Need a Magnetizing Current
A PMSM carries its field with it, baked into the rotor magnets. An induction motor, or ACIM, has no magnets. Its rotor is a cage of conductors with nothing to magnetize it on its own. The flux has to come from the stator, and that is the job of the magnetizing current.
In FOC the stator current splits into two parts. One part, Id, builds the rotor flux. The other part, Iq, produces torque against that flux. Torque in an induction motor is roughly the product of the rotor flux and Iq, so without flux there is nothing for Iq to push against. That is why a PMSM typically runs with Id near zero while an induction motor needs a real, nonzero Id at all times.

The magnetizing branch in the equivalent circuit above is the inductance M in the middle. Id is the current that flows through it to set up the air-gap flux. For more on how this motor type works, see our guide to the induction motor.
Takeaway: no magnets means you have to supply the flux yourself, and Id is the current that does it.
Id and Iq in the d-q Frame for ACIM
FOC controls the motor in a rotating frame called the d-q frame, aligned with the rotor flux. In that frame the two current components become two separate knobs:
- Id sets the rotor flux. It is the magnetizing current.
- Iq sets the torque, working against the flux that Id created.
SOLO runs this loop for you. The controller measures the phase currents, transforms them into Id and Iq, then drives each one to its target with its own PI controller. For an induction motor, SOLO holds Id at the value you choose so the rotor flux stays roughly constant, and it varies Iq to follow your speed or torque command.
The split matters because it lets you tune flux and torque on their own. You pick a flux level with Id once, and from then on the torque loop handles the work. If Id is wrong, every torque command after it inherits the error.

Takeaway: Id is the flux knob, Iq is the torque knob, and SOLO keeps both under closed-loop control.
How to Size the Magnetizing Current
There is no single right number for Id. It depends on the motor. A good value sets enough flux to reach rated torque without pushing the iron into saturation, where extra current stops adding flux and only adds heat. You get there in two steps: start from the nameplate, then trim by hand.
Starting From Nameplate Data
The best starting point is the motor’s no-load current. When an induction motor spins free with no load, almost all of the current it draws is magnetizing current. So the no-load current is close to the Id you want.
If the datasheet lists a no-load current, start there. If it does not, a common rule of thumb is that the magnetizing current sits around 30 to 50 percent of the rated current for a typical industrial induction motor. Smaller and high-efficiency motors can land lower. Use this only as a first guess, then verify by running the motor.
Tuning Id Empirically
Once you have a starting value, refine it on the bench. Raise Id in small steps and watch two things: the torque the motor can produce, and how warm it gets. As you increase Id, torque capability rises at first, then flattens out as the iron saturates. Past that point you are adding heat, not torque. The sweet spot sits just below where torque stops climbing.
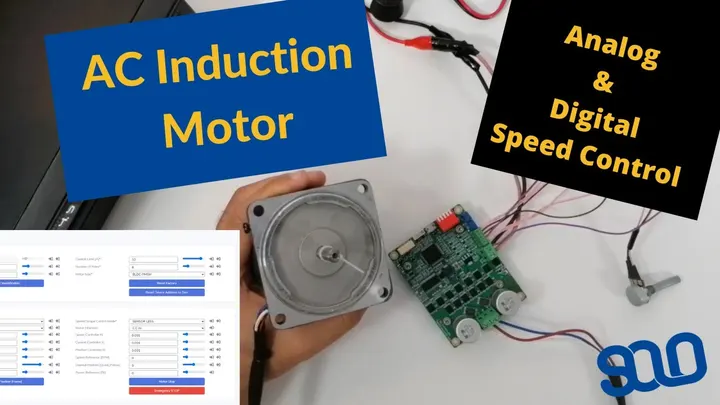
If the motor feels weak under load, try a bit more Id. If it runs hot at idle or light load, you are likely past the saturation point and should pull Id back. The video below walks through running an ACIM with SOLO, in both manual and digital modes, which is a clean way to test these changes.
Takeaway: start at the no-load current, then nudge Id up or down while you watch torque and temperature.
Setting Id in Motion Terminal
You set the magnetizing current as a parameter in SOLO Motion Terminal. After you select the induction motor type and run the basic identification, the controller exposes the Id reference you can adjust. Enter your starting value, apply it, and run the motor.
If you have not set up the motor yet, do that first. A clean first setup, connecting, identifying the motor, and getting a first stable spin, makes the Id tuning afterward much easier. The Id value you choose only behaves well once the rest of the loop is configured.
Verifying With the Oscilloscope
Motion Terminal has a built-in scope that plots the live signals. Add Id and Iq to the plot and run the motor. You want to see Id hold steady at your target while Iq moves with the load. If Id wanders or cannot reach its target, the current loop or the supply may be the limit, not the value you entered.
Watching Id and Iq live is the fastest way to confirm the motor is doing what you asked. A steady Id and a clean Iq that tracks load is the picture you are after.
Takeaway: set Id as a parameter, then use the scope to confirm Id holds steady while Iq follows the load.
Trade-offs: Torque, Efficiency and Heat
Choosing Id is a balance. More flux gives more torque headroom, but it costs current and heat. Less flux runs cooler at light load, but caps the torque the motor can make. The table below sums up what moves when you change Id.
| Id setting | Rotor flux | Torque capability | Losses and heat | Best for |
|---|---|---|---|---|
| Too low | Weak | Limited, motor feels soft | Low at idle, but high current needed for torque | Light, steady loads only |
| Well sized | Rated | Full rated torque available | Balanced | Most applications |
| Too high | Saturated | No real gain past saturation | High, wasted as heat | Nothing, avoid |
The pattern is simple. Below the right value you trade away torque. Above it you trade away efficiency. A well-sized Id gives you rated torque at the lowest heat the motor can manage.
One more case worth knowing: at high speed you may deliberately lower Id to spin faster than the base speed allows, the same idea as field weakening on a PMSM. That is a speed trade, not a tuning mistake, and it generally reduces available torque while it does so.
Takeaway: size Id for rated torque at the lowest heat, and only drop it on purpose when you need extra speed.
How SOLO Helps You Set the Magnetizing Current
SOLO controllers run FOC for AC induction motors out of the box, with the d-q current loops already in place. Motion Terminal gives you the Id reference as a parameter and a live scope to check Id and Iq while the motor runs, so you can size the magnetizing current by watching real signals instead of guessing. SOLO also supports both manual and digital tuning workflows, which helps you trim Id quickly on the bench. You can try this on any SOLO controller that drives an induction motor.
Conclusion
An induction motor needs a magnetizing current, Id, because it has no magnets to supply the rotor flux on its own. Id sets the flux, Iq sets the torque, and the two are controlled on their own in the d-q frame. Start Id near the motor’s no-load current, then trim it on the bench while you watch torque and temperature, since too little Id means weak torque and too much means wasted heat. SOLO Motion Terminal lets you set Id as a parameter and verify it live on the scope. The fastest way to dial it in is to set up the motor in Motion Terminal and watch Id and Iq while you tune.
FAQ
What is a good starting value for Id on an induction motor?
Start at the motor’s no-load current, which is mostly magnetizing current. If the datasheet does not list it, a common first guess is 30 to 50 percent of the rated current for a typical industrial induction motor. Treat it as a starting point, then trim it on the bench while you watch torque and temperature.
Does a PMSM need a magnetizing current too?
No, not in normal operation. A PMSM carries its field in the rotor magnets, so you usually hold its Id near zero. The exception is field weakening at high speed, where you drive Id negative on purpose to spin faster. An induction motor is different because it always needs Id to create the rotor flux.
Why does my induction motor have low torque?
Low Id is a common cause. Without enough magnetizing current there is little rotor flux, so the torque-producing current Iq has little to work against. Try raising Id toward the no-load current and check the torque again. If torque still does not rise, look at the current limit and the supply voltage, which can also cap available torque.
Can too much Id overheat the motor?
Yes. Past the point where the iron saturates, extra Id stops adding flux and only adds current, which turns into heat in the windings. If the motor runs hot at idle or light load, lower Id and watch whether torque capability drops. If torque holds while the motor cools, you were running too much Id.
Related articles
Torque Constant (Kt): How SOLO Converts Current to Torque
Torque constant (Kt) explained: how torque = Kt x Iq turns current into torque, why Kt matters for sizing, and how SOLO Motion Terminal shows the relationship.
Stall Detection and Motor Protection Setup on SOLO
Set up stall detection and motor protection on SOLO: configure the stall time, current and fault response to protect your motor from a locked rotor.
PWM Frequency Selection for Low-Inductance Motors
How to choose the PWM switching frequency on SOLO, why low-inductance motors need a higher frequency, and the trade-offs with heat and ripple.
