
Speed Acceleration and Deceleration: Smooth Ramps and Regeneration
Introduction
Ask a motor to jump from 0 to 3000 RPM in a single step and the result is rarely clean. You get a mechanical jolt, a current spike that can trip the drive, and speed overshoot before the loop settles. A motor acceleration ramp fixes that. It limits how fast the speed command can change, so the motor reaches the target along a controlled slope instead of a vertical wall.
This article shows you how to set the acceleration and deceleration ramps for smooth motion, and why the deceleration ramp matters even more than the acceleration one. When a motor slows down, it turns into a generator and pushes energy back at your power supply. Get the decel ramp right and that energy stays under control.
What Acceleration and Deceleration Ramps Do
A ramp limits the rate of change of speed over time. Instead of commanding a new speed instantly, the controller walks the setpoint up or down at a fixed slope, usually expressed in RPM per second. The acceleration ramp governs speed-up, the deceleration ramp governs slow-down, and the two are set independently.
The effect shows up in three places. First, current: torque is proportional to current, and accelerating an inertial load needs torque, so a steeper ramp demands more current. A ramp that is too aggressive pushes the drive into its current limit, and the motor can no longer follow the command. Second, mechanics: sudden speed changes load gears, belts, and couplings with shock that wears them faster. Third, the motion itself: a gentle ramp removes the overshoot and jerk you feel as a jolt in a robot arm or a conveyor.

Takeaway: a ramp trades a little response time for smoother motion, lower current peaks, and longer mechanical life.
Setting the Acceleration Ramp
Pick the acceleration value from two limits: the inertia you have to move and the torque the motor and drive can deliver. Acceleration needs torque, and torque needs current. If you set the ramp faster than the available torque allows, the controller saturates at its current limit and the actual speed falls behind the commanded ramp. The motion is no longer what you asked for.
A practical method is to start conservative and tighten. Begin with a ramp that reaches target speed in, say, one second, confirm the motor follows it without hitting the current limit, then shorten the time in steps. Watch the current while you do this. The moment current pins to its ceiling during the ramp, you have found the floor, so back off slightly for margin. Heavier loads and higher target speeds both need gentler ramps for the same drive.
As a rule, set the acceleration so the drive stays a comfortable margin below its current limit during the steepest part of the ramp.
Setting the Deceleration Ramp
Deceleration looks like the mirror image of acceleration, but it is not symmetric in one important way. Slowing a spinning load down means taking energy out of it, and that energy has to go somewhere. Where it goes decides how aggressive your deceleration ramp can safely be.
Why Decel Generates Energy
When you accelerate, the motor draws energy from the bus and puts it into the load as motion. When you decelerate, the flow reverses. The spinning load now drives the motor, the motor acts as a generator, and it converts that kinetic energy back into electrical energy. This is the basis of regenerative braking: the braking effort produces current that flows back toward the power source instead of being thrown away as heat.

The faster you decelerate, the more power the motor generates, because power is energy divided by time. A long, gentle decel returns the same total energy slowly. A short, hard decel returns it in a burst. For the full picture of how this recovery works, see our guide to regenerative braking.
Decel, Regeneration and the Bus Voltage
That regenerated energy lands on the DC bus. If the source can absorb it, a battery for example, the energy recharges it and everyone is happy. If the source cannot absorb it, a typical unidirectional power supply for example, the energy has nowhere to go and it charges up the bus capacitor instead. The result is a bus voltage rise. Decelerate hard enough and that rise becomes an overvoltage spike that can trip the drive or stress the capacitors.
This is the direct link between your deceleration ramp and your regeneration limit. A steeper decel ramp means a higher regenerated current and a bigger voltage push on the bus. Keep the decel ramp gentle, or cap the regenerated current, and the bus stays in range. If your application genuinely needs hard braking, the usual answer is a brake resistor, a chopper circuit that burns the surplus energy as heat so the bus does not climb.
Takeaway: set the deceleration ramp not just for the motion you want, but for the energy your power source can safely swallow.
Ramps vs Motion Profiles
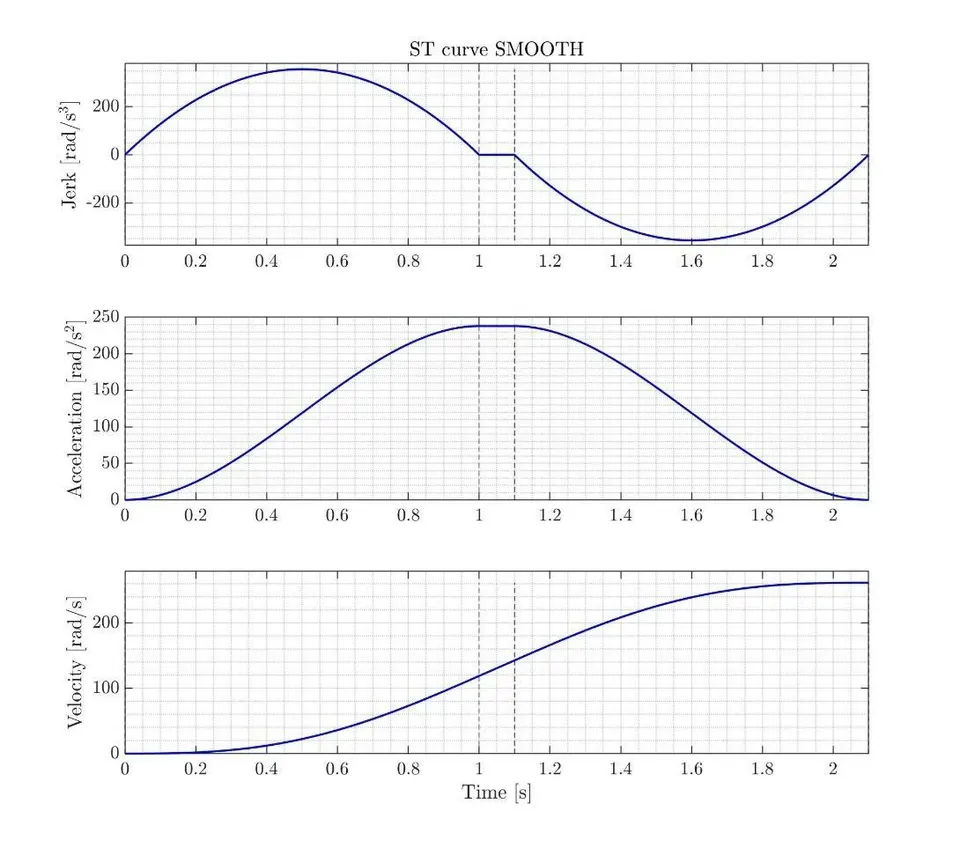
A linear ramp is the simple case. Speed changes at a constant rate, which means acceleration switches on and off as a step at the start and end of the ramp. That step in acceleration is jerk, the rate of change of acceleration, and high jerk is what you feel as a snap at the beginning and end of a move.
A motion profile, often an S-curve, rounds those corners. Instead of switching acceleration on instantly, it ramps the acceleration itself up and down, so the transitions are smooth and jerk stays low. The trade is a little extra time and complexity for noticeably gentler motion.
When do simple ramps suffice? In most speed-control jobs they are enough. Use the table below to choose.
| Need | Linear ramp | S-curve profile |
|---|---|---|
| Conveyors, pumps, fans | Fine, simple to set | Overkill |
| Mechanical shock concern | Acceptable | Better, lower jerk |
| Precise positioning, low vibration | Limited | Preferred |
| Setup effort | Low | Higher |
As a rule, reach for a ramp first. Step up to an S-curve profile only when jerk or vibration becomes a real problem.
Configuring Ramps in Motion Terminal
In Motion Terminal you set the acceleration and deceleration ramps as separate parameters, typically in RPM per second, alongside the speed setpoint. Because they are independent, you can use a brisk acceleration and a gentle deceleration, which is a common choice when the power source cannot absorb much regenerated energy.
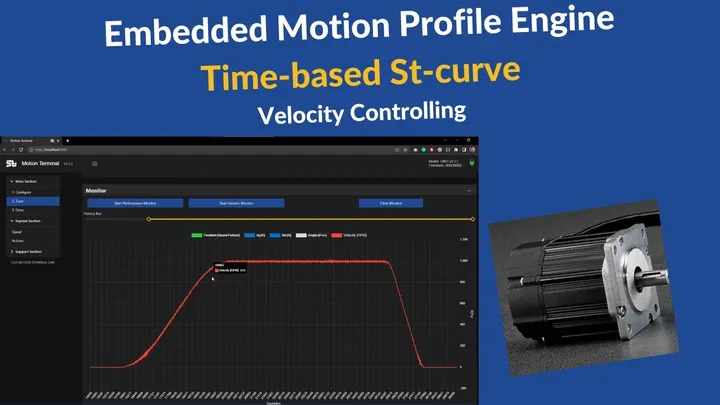
The reliable way to verify a ramp is to watch the actual speed, not just the command. Use the live monitoring view to plot commanded speed against measured speed during a move. If the two slopes match, the drive is following your ramp. If the measured speed lags the command, the ramp is steeper than the available torque allows, and you should ease it back. Plotting the current at the same time tells you whether you are hitting the current limit.
Takeaway: configure accel and decel separately, then confirm with a live plot that the motor actually follows the slope you set.
Tuning Ramps With the Speed Loop
Ramps and the speed loop gains work together, and tuning one affects the other. The ramp shapes the setpoint that the speed loop has to track. If the loop is tuned tight enough to follow that ramp without lag or overshoot, the motion is clean. If the loop is loose, even a gentle ramp produces a sloppy response, and the measured speed wanders around the command.
So tune in the right order. Get the speed loop responding well to a step first, then add the ramp to shape how the setpoint moves. A well-tuned loop following a sensible ramp gives you smooth, repeatable motion. A ramp cannot rescue a poorly tuned loop, and a tight loop cannot remove the shock of a missing ramp. They solve different problems and you need both.
How SOLO Helps You Shape Motion Ramps
SOLO controllers let you set acceleration and deceleration ramps as independent parameters, so you can shape speed-up and slow-down separately to match your load and your power source. In Motion Terminal you configure the ramps, set the current and regeneration limits that protect the bus during braking, and watch the live speed and current plots to confirm the motor follows the slope you asked for. The aim is to give you control over the motion and the energy, not just the final speed. You can explore the workflow on the SOLO Motion Terminal page.
Conclusion
Smooth motion comes down to two ramps set well. The acceleration ramp limits how fast speed rises, bounded by the torque and current you have available. The deceleration ramp limits how fast speed falls, and because slowing down turns the motor into a generator, a steep decel pushes energy back at the bus and can raise the voltage. Set acceleration for the load and the current limit, set deceleration for the motion and the energy your source can absorb, and verify both with a live plot. If you want to try this on your own setup, the SOLO Motion Terminal is the place to start.
FAQ
What happens if I set the deceleration ramp too aggressively?
The motor brakes harder, generates more current, and pushes more energy back onto the DC bus in a short time. If the power source cannot absorb it, the bus voltage rises and can trigger an overvoltage fault or stress the bus capacitors. Ease the decel ramp, lower the regeneration current limit, or add a brake resistor to give the energy a path.
Why does the bus voltage rise when the motor decelerates?
During deceleration the motor works as a generator and feeds energy back to the DC bus. A battery can absorb that energy, but a typical unidirectional power supply cannot. With nowhere to go, the energy charges the bus capacitor and the voltage climbs. The steeper the deceleration, the larger the rise.
Do I need a braking resistor for regeneration?
Not always. If your source can absorb the regenerated energy, a battery for example, no resistor is needed. You need a brake resistor when the source cannot take the energy back and your decel ramps are steep enough to push the bus voltage too high. The resistor burns the surplus energy as heat so the bus stays in range.
What is the difference between a ramp and an S-curve profile?
A linear ramp changes speed at a constant rate, which makes acceleration switch on and off as a step and produces high jerk at the start and end of a move. An S-curve profile smooths the acceleration itself up and down, so jerk stays low and the motion feels gentler. Ramps are simpler and fine for most jobs; S-curves are better when vibration or mechanical shock matters.
Related articles
Setting Current and Regeneration Limits on SOLO Safely
How to set the motor current limit and regeneration limit on SOLO to protect your motor, controller and power supply, with safe values.
Motion Profile Design on SOLO: Time-Based vs Time-Optimal St-Curve
Design smooth, low-jerk S-curve motion profiles on SOLO. Time-based vs time-optimal St-curve, jerk and acceleration limits, and setup in Motion Terminal.
Stall Detection and Motor Protection Setup on SOLO
Set up stall detection and motor protection on SOLO: configure the stall time, current and fault response to protect your motor from a locked rotor.
