
C++ Motor Controller
Build high-performance motor control applications with our open-source C++ library. Supports USB and CANopen communication.
Implement Your Own Algorithms
Looking for a powerful way to control motors with C++?
SOLO motor controllers CPP library, supported by all SOLO Motor Controllers, is a simple-to-use, comprehensive, and maintained library built on top of our Digital Protocol.
Digital Protocol

Guide
1. Easy Install
SOLO Motor Controllers CPP library is fully Open Source and available on GitHub. Download it and start building.
Github

2.1. Setup
There are several ways to connect your system to your SOLO motor controller.
Alternatives:
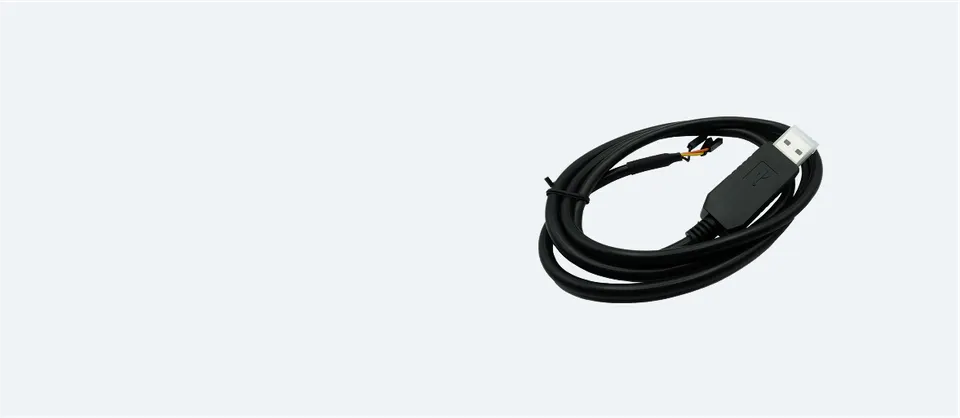
- USB port [need a USB data Cable]
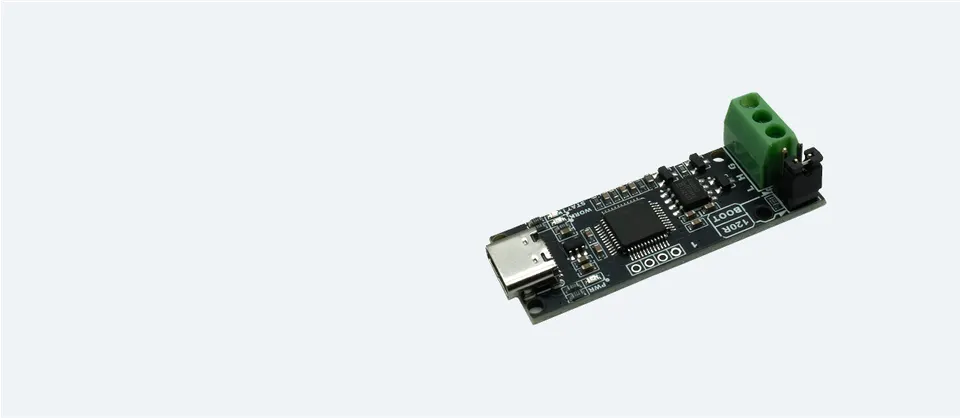
- CAN pins (CH, CL, GND) [need Kvaser]
Solo Pico

Solo Mini

Solo Uno

Solo Mega

2.2. Accessories
3. Code Example
USB
#include <iostream>
using std::cout;
using std::endl;

#include <conio.h>
#include "SOLOMotorControllersSerial.h"

int main(void)
{
    SOLOMotorControllers *solo = new SOLOMotorControllersSerial((char*)"COM3");
    boolean status;
    float readingValue;

    //READ INPUT VOLTAGE:
    readingValue = solo->GetBusVoltage();
    std::cout << "Succesfully read from solo, Value: " << readingValue << std::endl;

    //DISCONNECT THE SOLO UNIT:
    solo->Disconnect();
}
In the example, the PC is connected to the Motor Controller using the USB port (Data USB Cable needed).
CANopen
#include <iostream>
using std::cout;
using std::endl;

#include <conio.h>
#include "SOLOMotorControllersCanopenKvaser.h"

int main(void)
{
    SOLOMotorControllers *solo = new SOLOMotorControllersCanopenKvaser();
    boolean status;
    float readingValue;

    //READ INPUT VOLTAGE:
    readingValue = solo->GetBusVoltage();
    std::cout << "Succesfully read from solo, Value: " << readingValue << std::endl;

    //DISCONNECT THE SOLO UNIT:
    solo->Disconnect();
}
In the example, the PC is connected to the Motor Controller using the CANopen protocol (Kvaser needed).

CANopen support
For demanding and industry-standard applications, the library supports the CANopen protocol. It’s as simple to use as UART, with minimal differences, but significantly more robust: high-intensity communication, superior error handling, and full networking capabilities under harsh conditions.
SOLO motor controllers CPP library is a single library that contains both UART and CANopen capabilities.
In order to use CANopen, you need the Kvaser solution.
In order to use CANopen, you need a USB-to-CAN adapter such as our CANable V2.0.
