
Python Motor Controller
Control motors and automated systems with Python across Windows, Linux and Raspberry Pi. Supports USB, UART and CANopen communication.


Guide
1. Choose your OS
Python is supported on several OS and hardware platforms. Here is a list of the systems we cover in our Articles and Tutorials.


2. Install SoloPy
SoloPy is fully Open Source and available on GitHub. Install it using PIP in a convenient and standard way.
Pip command in the terminal:
- Windows:
python -m pip install SoloPy - Linux:
pip install SoloPy - Raspberry Pi:
pip install SoloPy
3.1. Setup
There are several ways to connect your system to your SOLO motor controller.
Alternatives:
- USB port [need a USB data Cable]
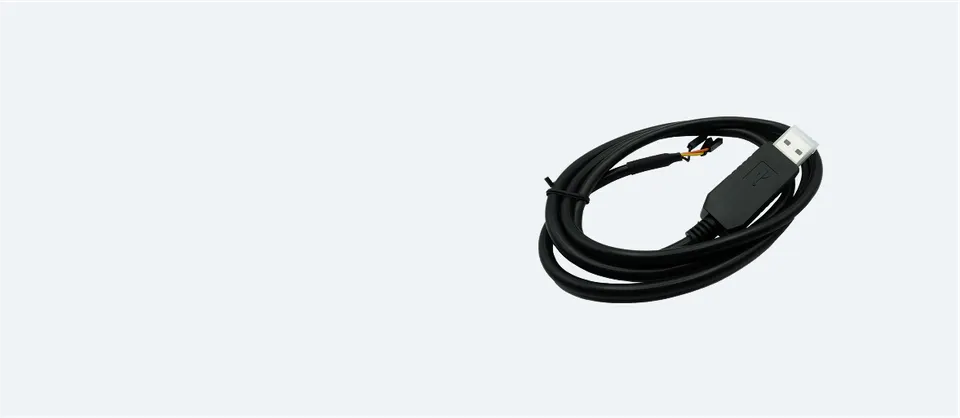
- UART pins (TX, RX, GND) [need a USB-to-UART adapter]
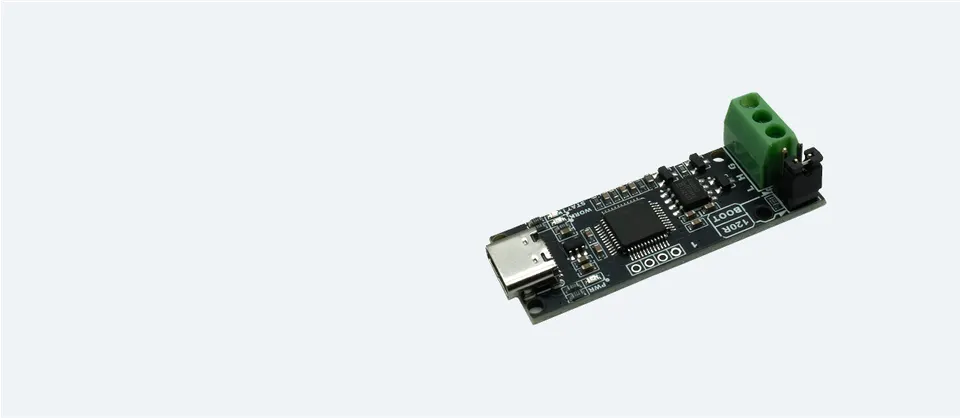
- CAN pins (CH, CL, GND) [need a USB-to-CAN adapter]
Solo Pico

Solo Mini

Solo Uno

Solo Mega

3.2. Accessories
4. Code Example
Here are some examples. You can also check the Repo/Examples, the Documentation or our Articles to better know our library.
Windows - USB
import SoloPy as solo
import time

mySolo = solo.SoloMotorControllerUart("COM3")

while True:
    print("Read from SOLO the Board Temperature: " + str(mySolo.get_board_temperature()))
    print("Read from SOLO the Motor Speed: " + str(mySolo.get_speed_feedback()))
    time.sleep(1)
In the example PC is connected to the Motor Controller with a USB data cable.
Linux - USB
import SoloPy as solo
import time

mySolo = solo.SoloMotorControllerUart("/dev/ttyACM0")

while True:
    print("Read from SOLO the Board Temperature: " + str(mySolo.get_board_temperature()))
    print("Read from SOLO the Motor Speed: " + str(mySolo.get_speed_feedback()))
    time.sleep(1)
In the example PC is connected to the Motor Controller with a USB data cable.
Raspberry Pi - UART
import SoloPy as solo
import time

mySolo = solo.SoloMotorControllerUart("/dev/ttyS0")

while True:
    print("Read from SOLO the Board Temperature: " + str(mySolo.get_board_temperature()))
    print("Read from SOLO the Motor Speed: " + str(mySolo.get_speed_feedback()))
    time.sleep(1)
In the example Raspberry Pi UART (TX, RX) and GND pins are connected to the UART (RX, TX) and GND pins of the Motor Controller.
Raspberry Pi - CANopen
import SoloPy as solo
import time

#CANOpen module require Raspberry extra configuration + extra command before run the example
mySolo = solo.SOLOMotorControllersCanopen(0)

while True:
    print("Read from SOLO the Board Temperature: " + str(mySolo.get_board_temperature()))
    print("Read from SOLO the Motor Speed: " + str(mySolo.get_speed_feedback()))
    time.sleep(1)
In the example Raspberry Pi Module CAN (CH, CL) and GND pins are connected to the CAN (CH, CL) and GND pins of the Motor Controller
The following CAN transceiver module “PiCAN2” has been used to test the Example

CANopen support
For demanding and industry-standard applications, the library supports the CANopen protocol. It’s as simple to use as UART, with minimal differences, but significantly more robust: high-intensity communication, superior error handling, and full networking capabilities under harsh conditions.
SoloPy is a single library that contains both Serial/UART and CANopen capabilities.
In order to use CANopen, you need a USB-to-CAN adapter such as our CANable V2.0.
Python Articles


The Easiest way to control the Torque of a BLDC with Raspberry Pi using SOLO with Hall sensors feedback [+ Code]


